Tradeoffs in building dexterous robotic hands
What are the tradeoffs in building dexterous robotic hands? To answer this question, let us examine the two main approaches to building them.
The first approach is tendon-driven hands, with remote motors driving finger joints using tendons. Some notable examples of this approach are Tesla’s Optima, Shadow Robot, 1x NEO, and Kyber Labs.
The second is micromotor-driven hands, with small motors and high gear ratios on every joint. These have been used by Covvi, Quji, Figure AI and Psyonic.
These two mainstream approaches lead to different engineering tradeoffs. In the table below, we have summarized our understanding.
Dimension
Tendon-driven hands
Micromotor-driven
Payload
By moving the motor away from the hand onto the elbow, larger motors can be utilized. This makes hands strong enough to perform tasks like lifting up a bottle of water.
Micromotors’ torque is limited by their size — which, in turn, is constrained by the space available inside the robotic hand’s finger joints. To get sufficient range of motion, high gear ratios are used. This further limits the torque.
Heating
The position of the motor allows for easier heat dissipation.
Small size limits heat dissipation. Failure due to overheating is likely.
Sim-to-real gap
Tendons interact in a complex manner. Also, they stretch with use. This makes their behavior hard to model.
Micromotors have high inertia and high friction. Both of these properties are difficult to model, and cause a sim-to-real gap. Origami Robotics has an excellent blog post on this subject.
Degrees of freedom
Multiple tendons can affect a single joint, and vice versa. The more DoF we add, the more complex and failure-prone the system becomes.
Direct placement of the micromotor on the joint makes it easier to create hands with more DoF. Proponents of this approach claim that more DoF translates to greater capabilities.
Speed of movement
Lower inertia and friction enables higher speed.
To overcome inertia and friction safely, speed has to be limited.
We have represented this table as a radial chart. The numbers are our interpretation.
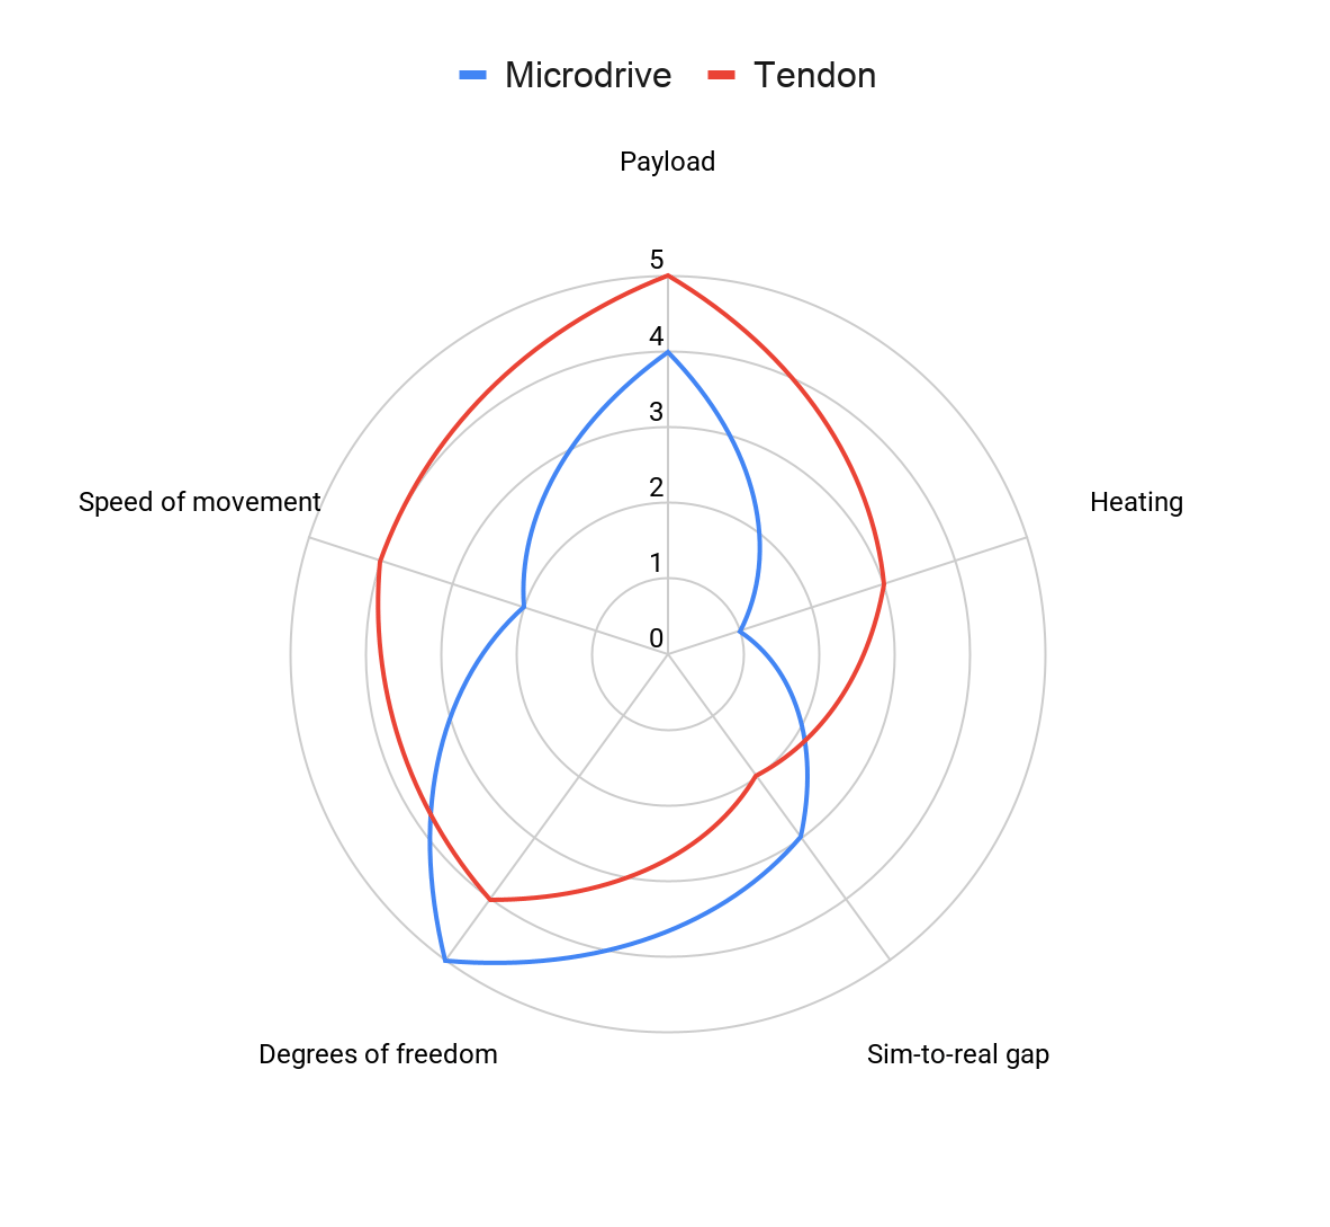
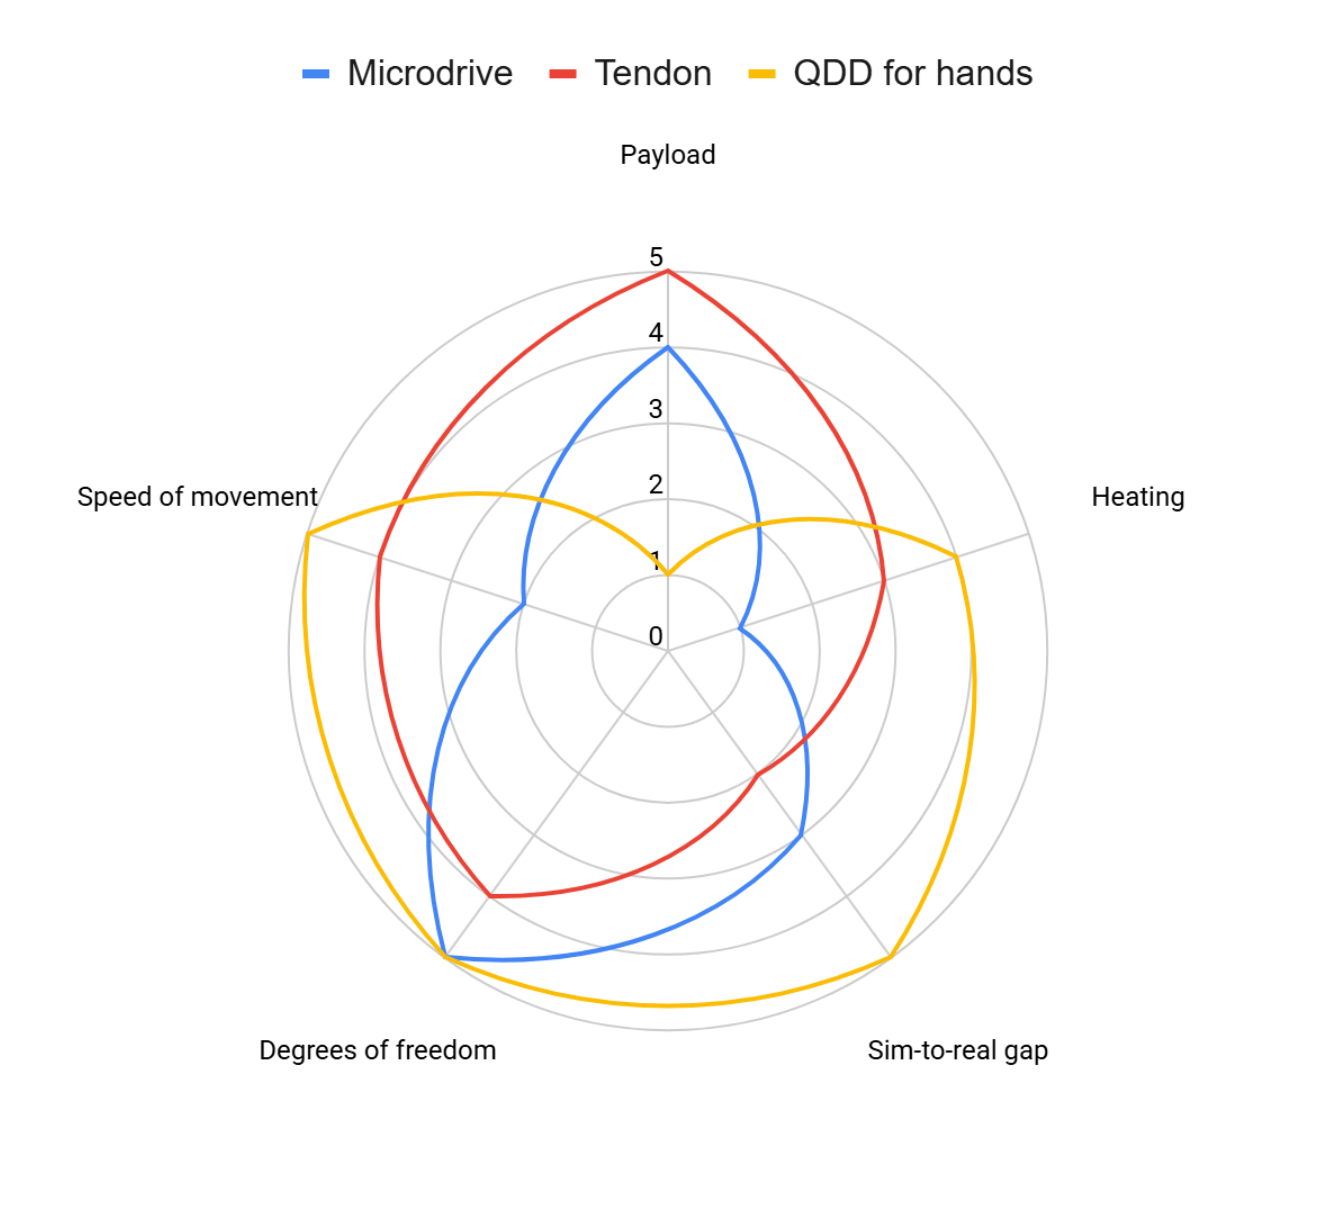
A third approach has also been deployed recently: that of using low gear ratios with micromotors—quasi-direct drives (QDD) for hands. QDD has already established itself in legged locomotion, but capping the gear ratio dramatically decreases payload. The benefits—more speed, responsiveness, and lower sim-to-real gap.
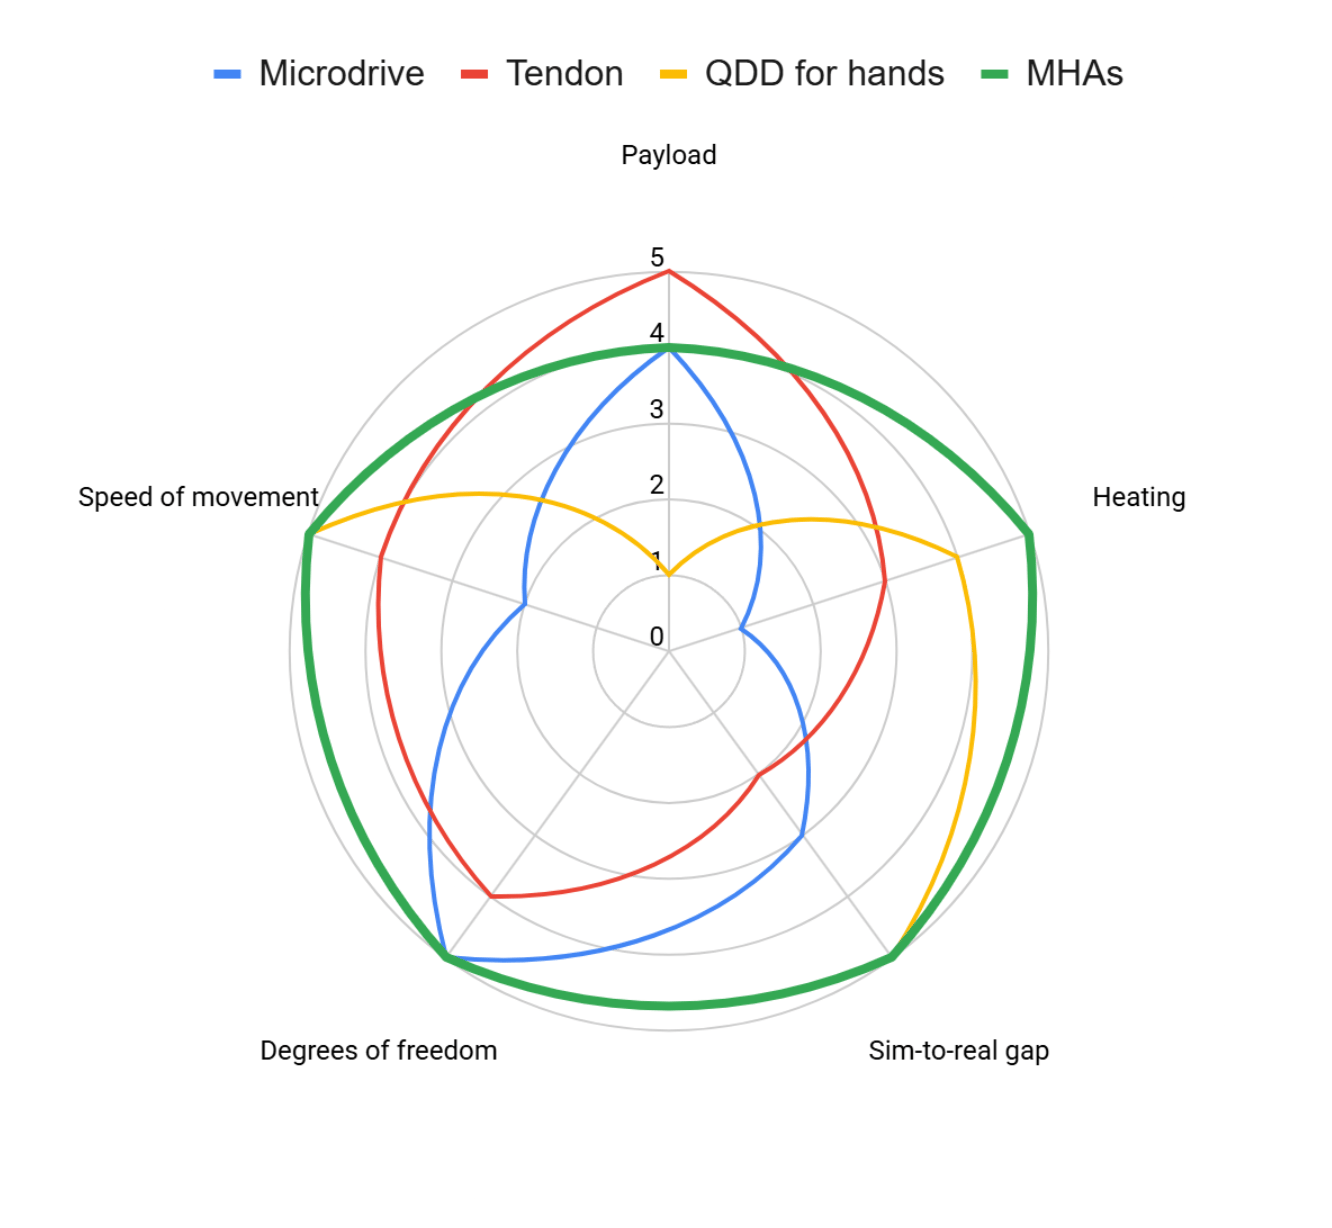
Microhydraulic actuators (MHAs) resolve this tradeoff, because they offer 100x the torque density of electromagnetic motors. Payload has yet to be maximized, because generating more force requires more wafers to be stacked.
On every other dimension, microhydraulic actuators provide best-in-class performance.
Read more
100x increase in torque density
Calculations that back up our performance claims.
The QDD Paradigm
An overview of quasi-direct drives. How they dominate humanoid legs, and Sangtera brings them to fingers.
Thermal management and zero-power hold
Electrostatics, but different. The science behind why only Sangtera can offer a motor with zero-power hold.